TartanDrive is selected as an outstanding learning paper finalist in ICRA2022

TartanDrive is selected as an outstanding learning paper finalist in ICRA2022

Published: by

TartanDrive is selected as an outstanding learning paper finalist in ICRA2022

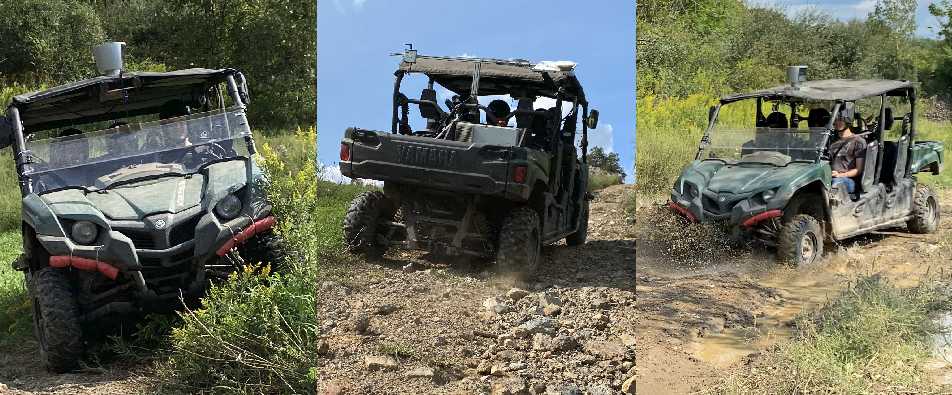
We took an all-terrain vehicle on wild rides through tall grass, loose gravel and mud to gather data about how the ATV interacted with a challenging, off-road environment.

The dataset and the paper are openly available. Read more about it in our linked article below:

Latest Research

Structured Perception Representations for Off-road Dynamics Learning

SpatialBEV predicts off-road robot dynamics by looking at terrain where it expects to drive

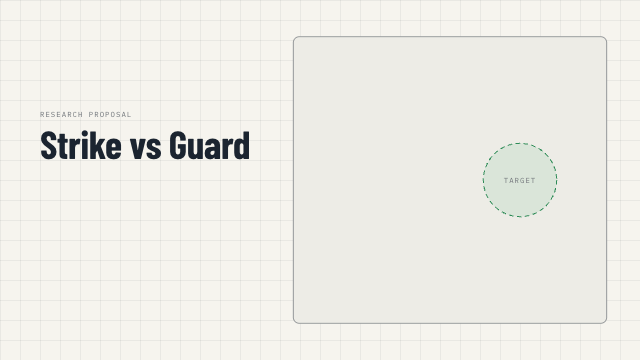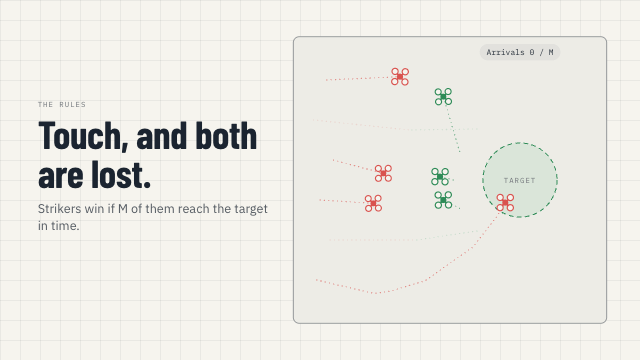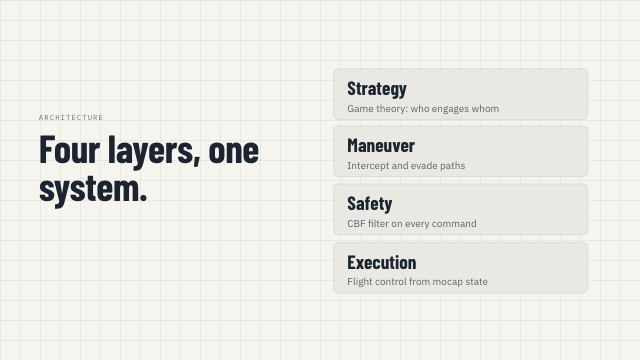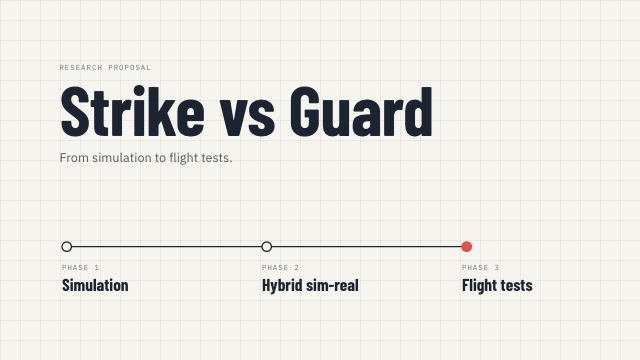
Strike vs Guard: Safe Ground Control for Drone Teams

Two identical drone teams, one protected target, and a ground controller that keeps every drone f...

SSIO: Self-Supervised Inertial Odometry

SSIO trains inertial odometry on unlabeled IMU data from normal operation — no costly ground truth.