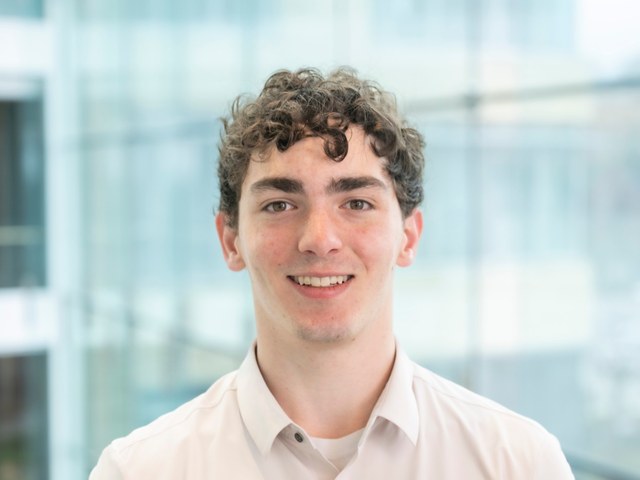
Carlton (Carl) Cort is an M.S. in Robotics (MSR) student and Rales Fellow at Carnegie Mellon University, working with Sebastian Scherer. Before CMU, he earned a B.S. in Electrical Engineering from Georgia Tech.
Carl is interested in making robots adaptive and safe enough to be reliable in real human environments. His master’s thesis focuses on risk-aware decision making and control for humanoids, building on uncertainty-aware, self-supervised proprioceptive state estimation. Within the AirLab, he works on the humanoid and inertial odometry teams.
Email: ccort@andrew.cmu.edu
LinkedIn: carlton-cort
Google Scholar: Carlton Cort
Website: carlcort.github.io